Xuanyun Qiu, Dorian Verdel, Hector Cervantes-Culebro, Alexis W.M. Devillard, Etienne Burdet·arXivPDF ↗︎abstract +
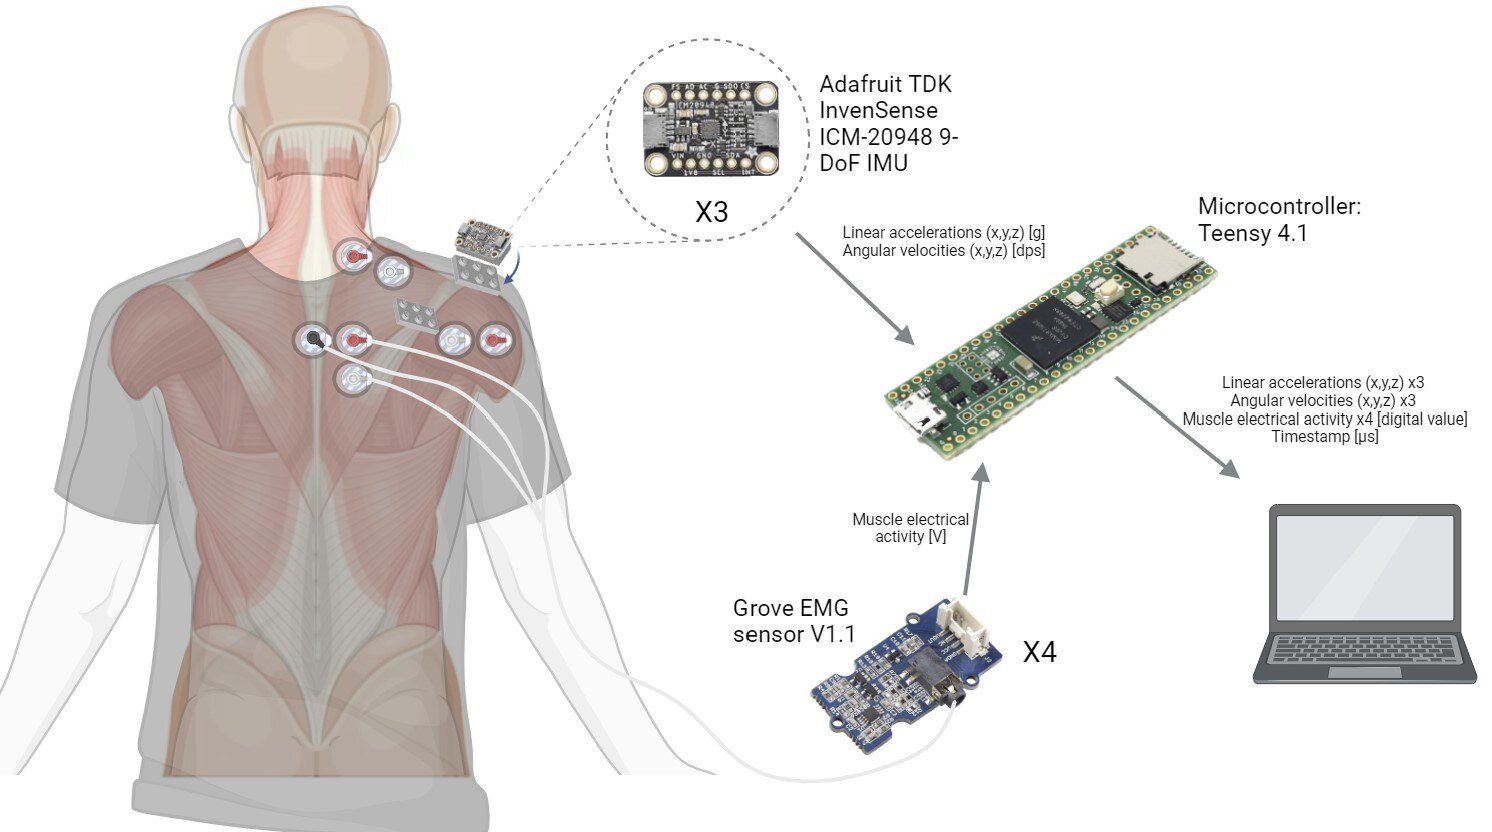
A hierarchical framework for maintaining balance when humans are augmented with supernumerary robotic limbs, featuring prediction, planning, and control layers tested with ten participants performing bending tasks.